ISIOS Service with Laser Sensor
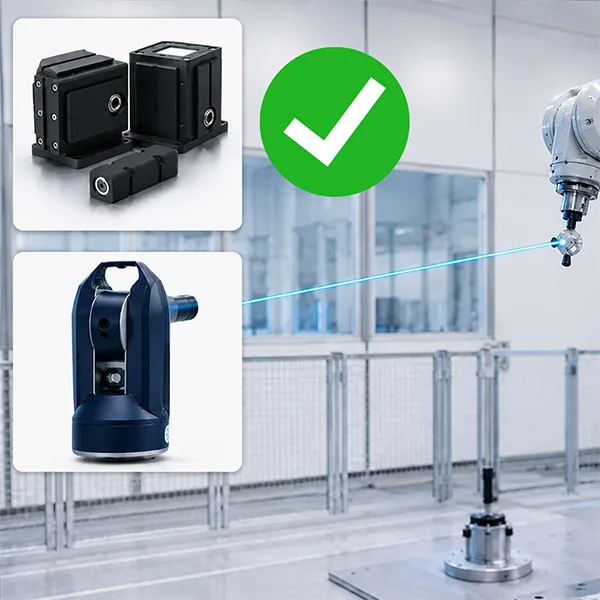
Maximum absolute accuracy with a laser tracker or the ISIOS Laser Sensor System. We calibrate…
Maximum Measurement Accuracy through High-Precision External Measurement
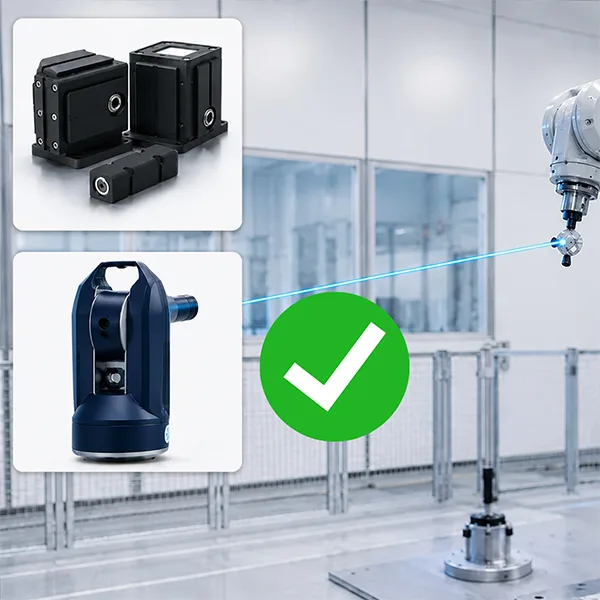
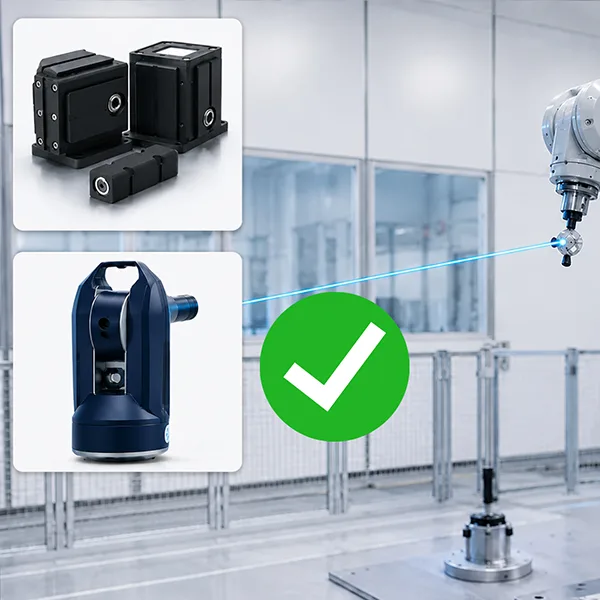
In laser tracker calibration, the actual robot pose is captured using a high-precision external measurement system. The robot moves to a large number of carefully selected positions and orientations within its workspace.
Based on this measurement data, ISIOS uses mathematical methods to identify all relevant kinematic parameters and other influencing factors that determine robot accuracy. Additional axes, such as linear axes, can also be included in the modelling. Parameter identification is then optimised and examined in detail for further accuracy potential.
The high accuracy of a laser tracker enables particularly precise measurements, making it especially suitable for demanding calibration tasks and applications with very high requirements for absolute pose and path accuracy.
The calibration results are then transferred to the robot controller. This allows the controller to account for systematic deviations between the nominal model and the real robot and to reach programmed precision poses significantly more accurately.
Suitable for:
high-precision machining, large workspaces, additional linear axes, complex robot installations and applications with particularly high pose and path accuracy requirements.